Product Details
Focusing on the core components of the IVD industry
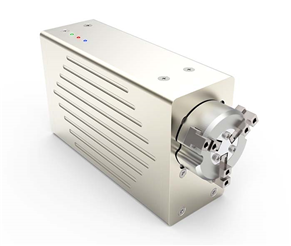
Rotating Electric Claw (WTEX28 / WTET28 Series)
  • Thumbnail 1
  • Thumbnail 2
  • Thumbnail 3
Rotating Electric Claw (WTEX28 / WTET28 Series)
Model: WTEX28 / WTET28 Integrated Rotary Gripper
  • Seamless integration of 360-degree continuous rotation and precision electric clamping
  • Intelligent torque sensing and feedback for automated sample tube capping and decapping
  • Hollow shaft design for clean cable routing and pneumatic pass-through
  • Compact modular structure, easily mounted on Cartesian robots or robotic arms
  • Programmable angle positioning, rotational speed, and finger clamp force
* CAD 3D models and PDF specification sheets are ready for immediate download. For custom OEM drawings, please contact our engineering team.
  • Product Details
  • Downloads
  • Videos

Product Overview & Description

WTEX28 and WTET28 series rotary grippers combine high-precision rotation with parallel clamping in a single motorized unit. Ideal for automated sample preprocessing, cap screwing, and sample vial sorting in medical laboratories.

Technical Specifications Table

Rotation RangeInfinite 360° Continuous
Rotational Torque0.2 N.m ~ 1.5 N.m (Torque feedback)
Clamping Force10 N ~ 60 N (Programmable)
Clamping Stroke12 mm ~ 25 mm
Repeat Accuracy+/-0.02° (Rotary) / +/-0.01 mm (Gripping)
Maximum Rotary Speed300 RPM
CommunicationRS485 / CANopen / IO Trigger
Application AreasBlood Collection Tube Decapping, Reagent Vial Capping, Centrifuge Loading

CAD & Documentation Downloads

📦 3D CAD Model (STEP / IGES)

Full 3D geometry with mechanical mounting holes and stroke clearance envelope.

Download 3D STEP →

📄 Engineering Drawing & Catalog (PDF)

Detailed dimensional drawings, wiring pinout diagrams, and performance curves.

Download PDF →

Product Demonstration & Testing Video

►

Rotating Electric Claw (WTEX28 / WTET28 Series) Demonstration Video

Watch real-world testing and assembly automation demonstrations in our Video Center.

Visit Video Center →